

Network-controlled DMX winch
WX8012
Bring your production into motion.
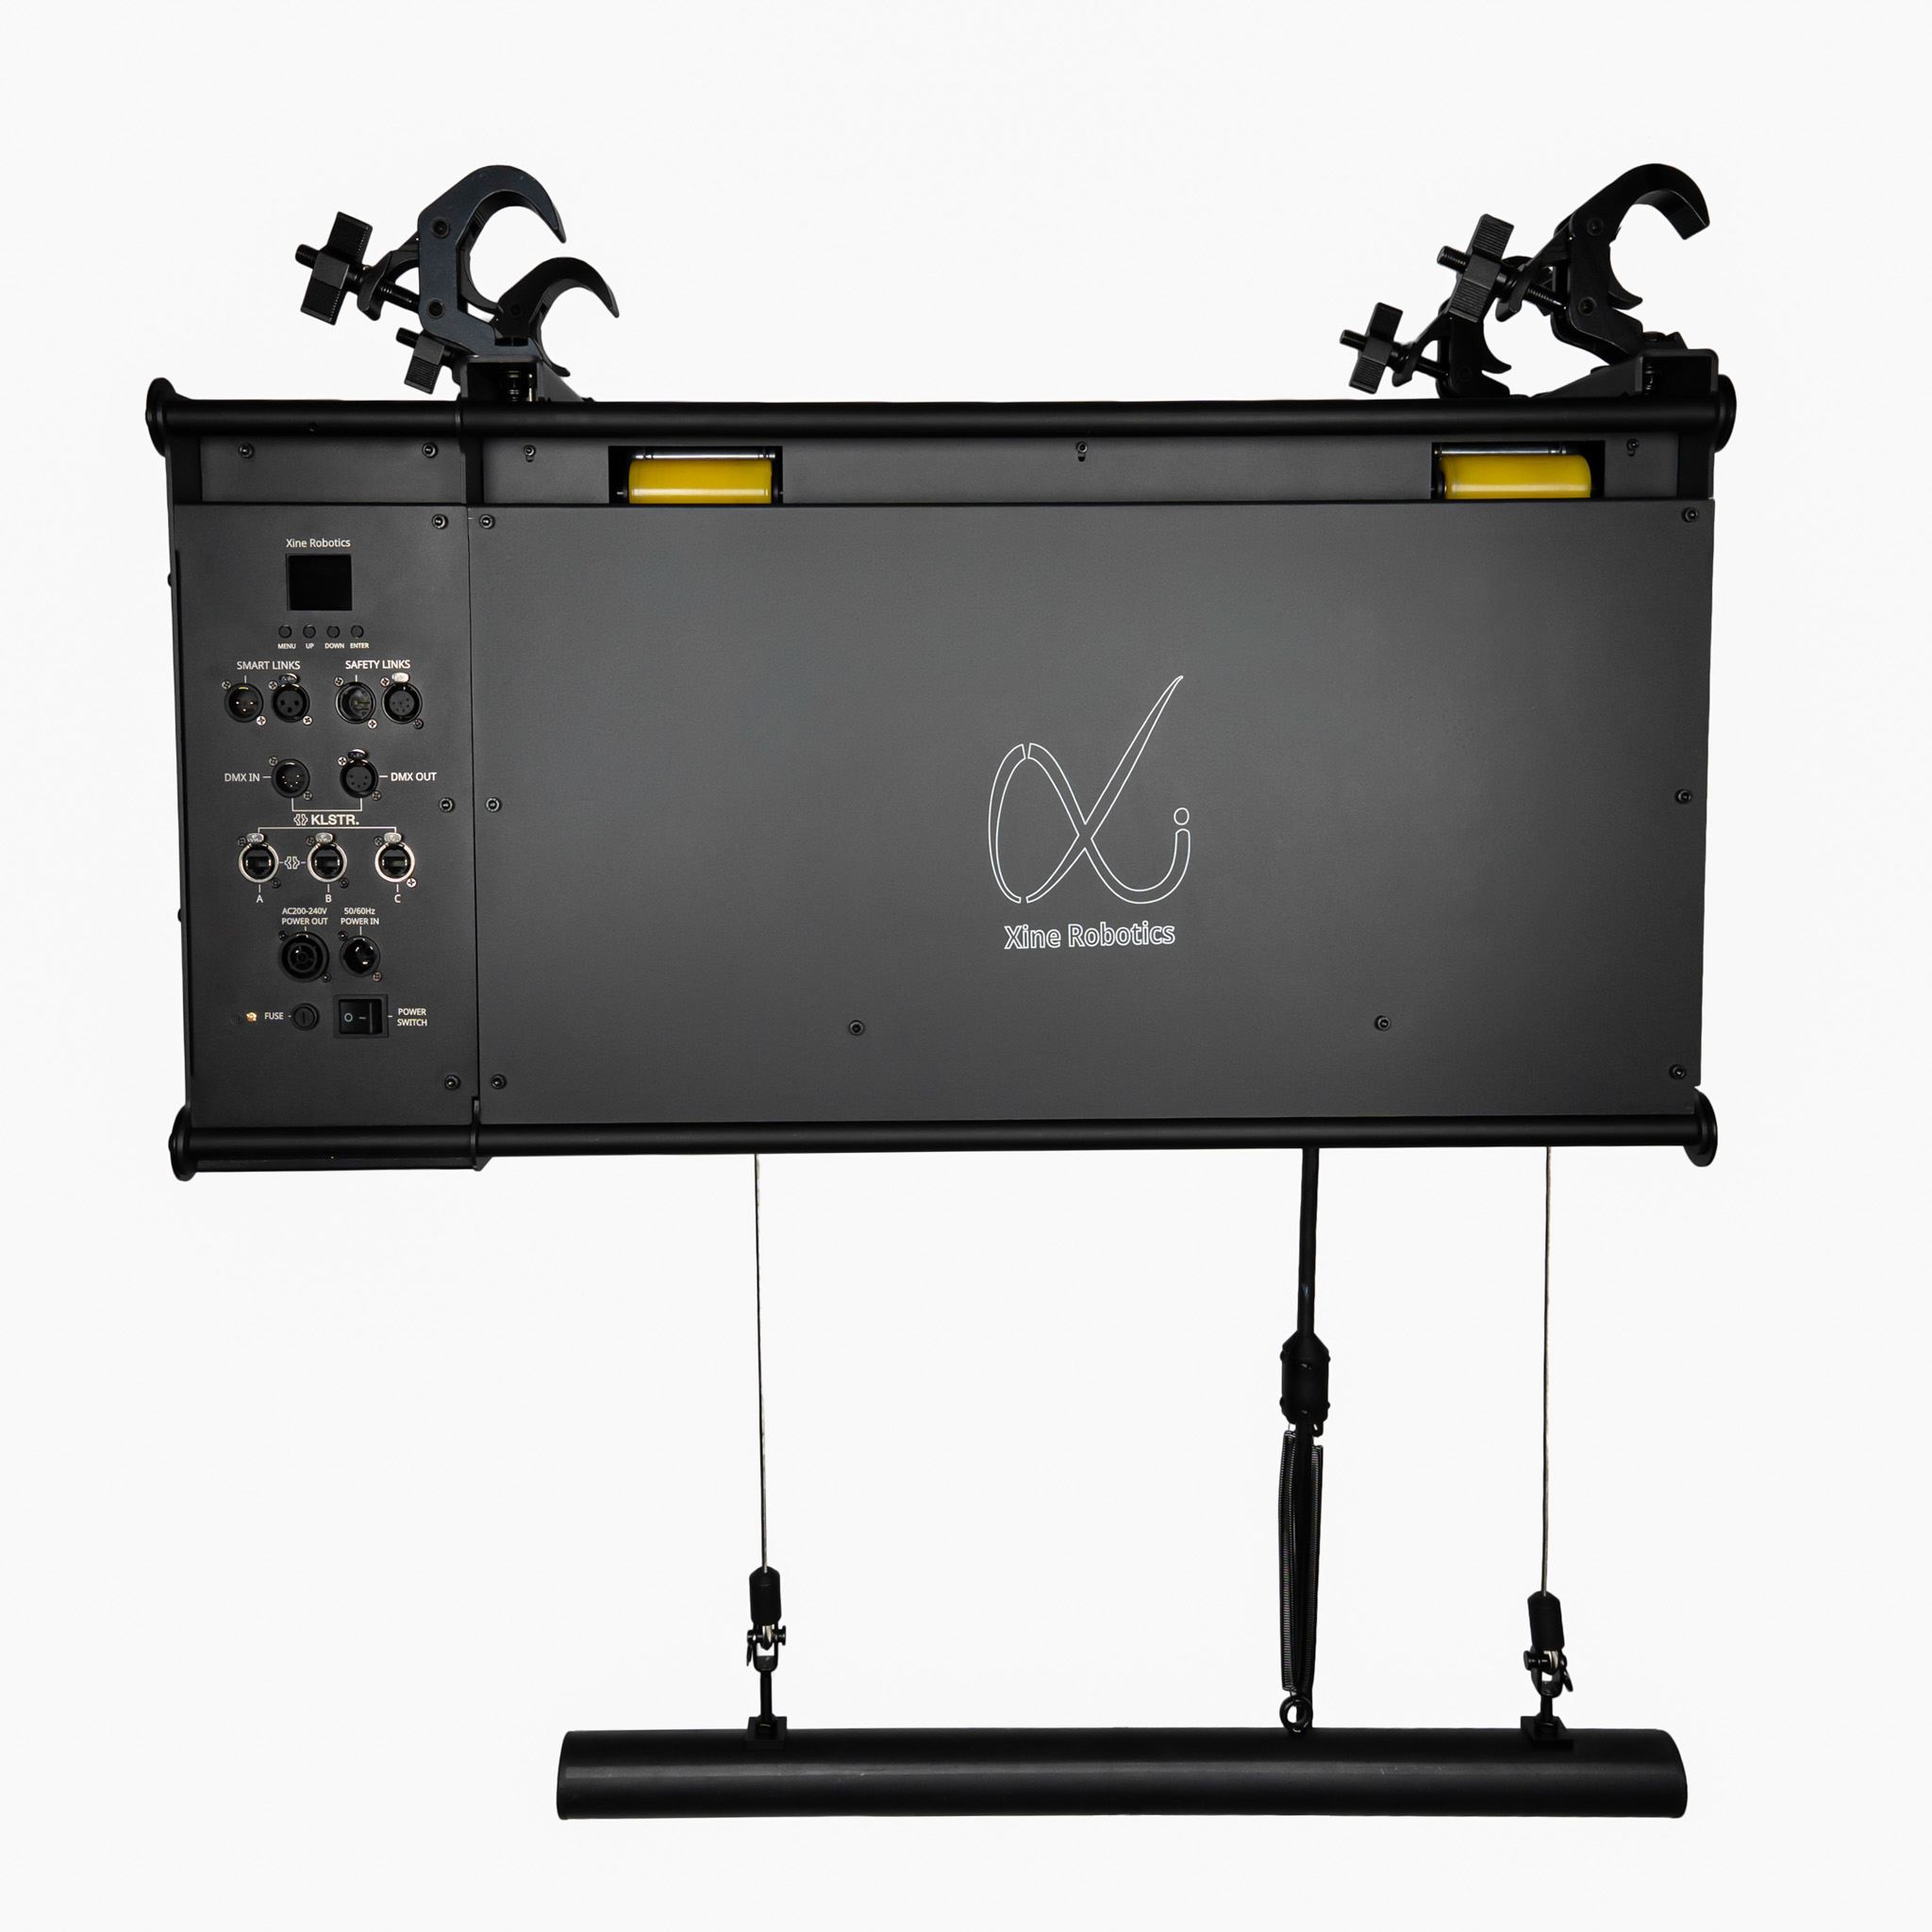
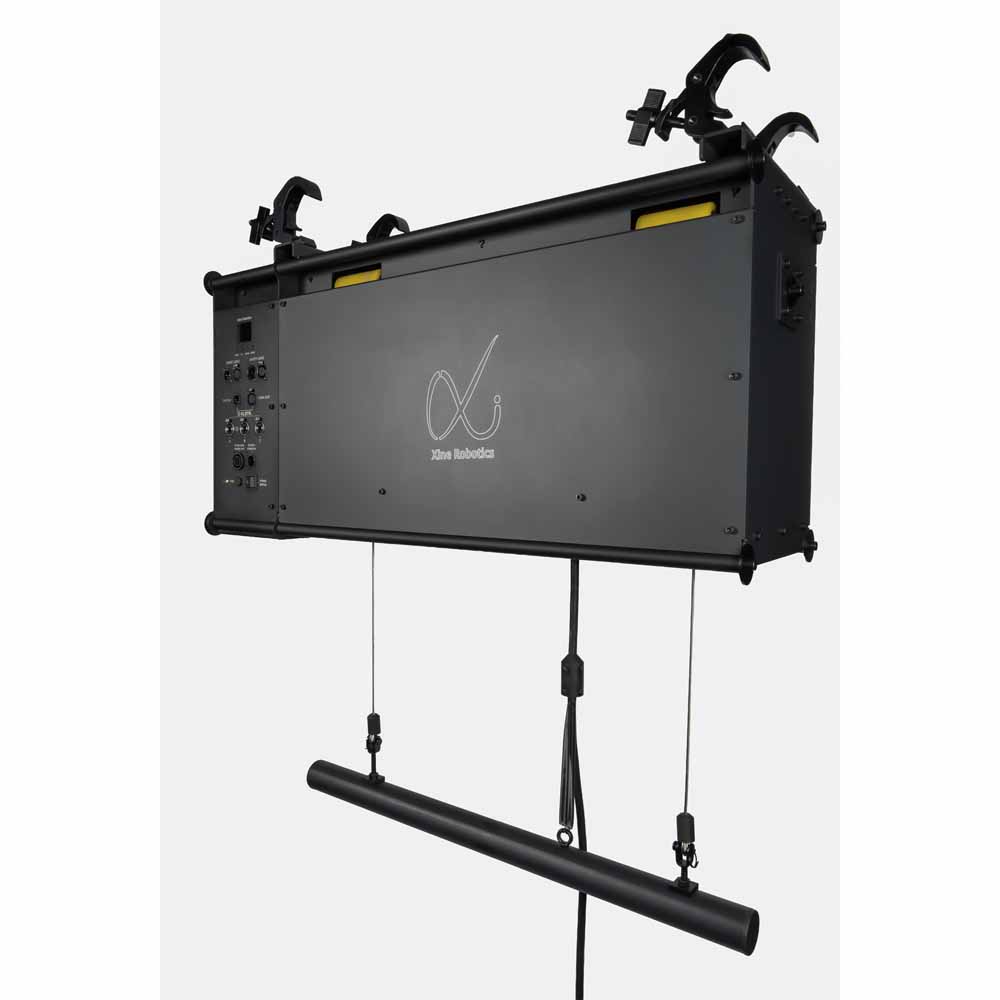
Explore the complete unit, an angled view and the connection panel.
WX8012 application informationThe WX8012 combines an 80 kg maximum lifting capacity with 12 m maximum lifting height and a 750 W servo motor. Control movement through DMX512, sACN or Artnet, with PowerCON TRUE 1 and EtherCON through connections.
80 kg
Maximum load
12 m
Maximum lifting height
100 cm/s
Maximum speed
Designed around your workflow
Your control setup. A new dimension of motion.
Control
Use your production network
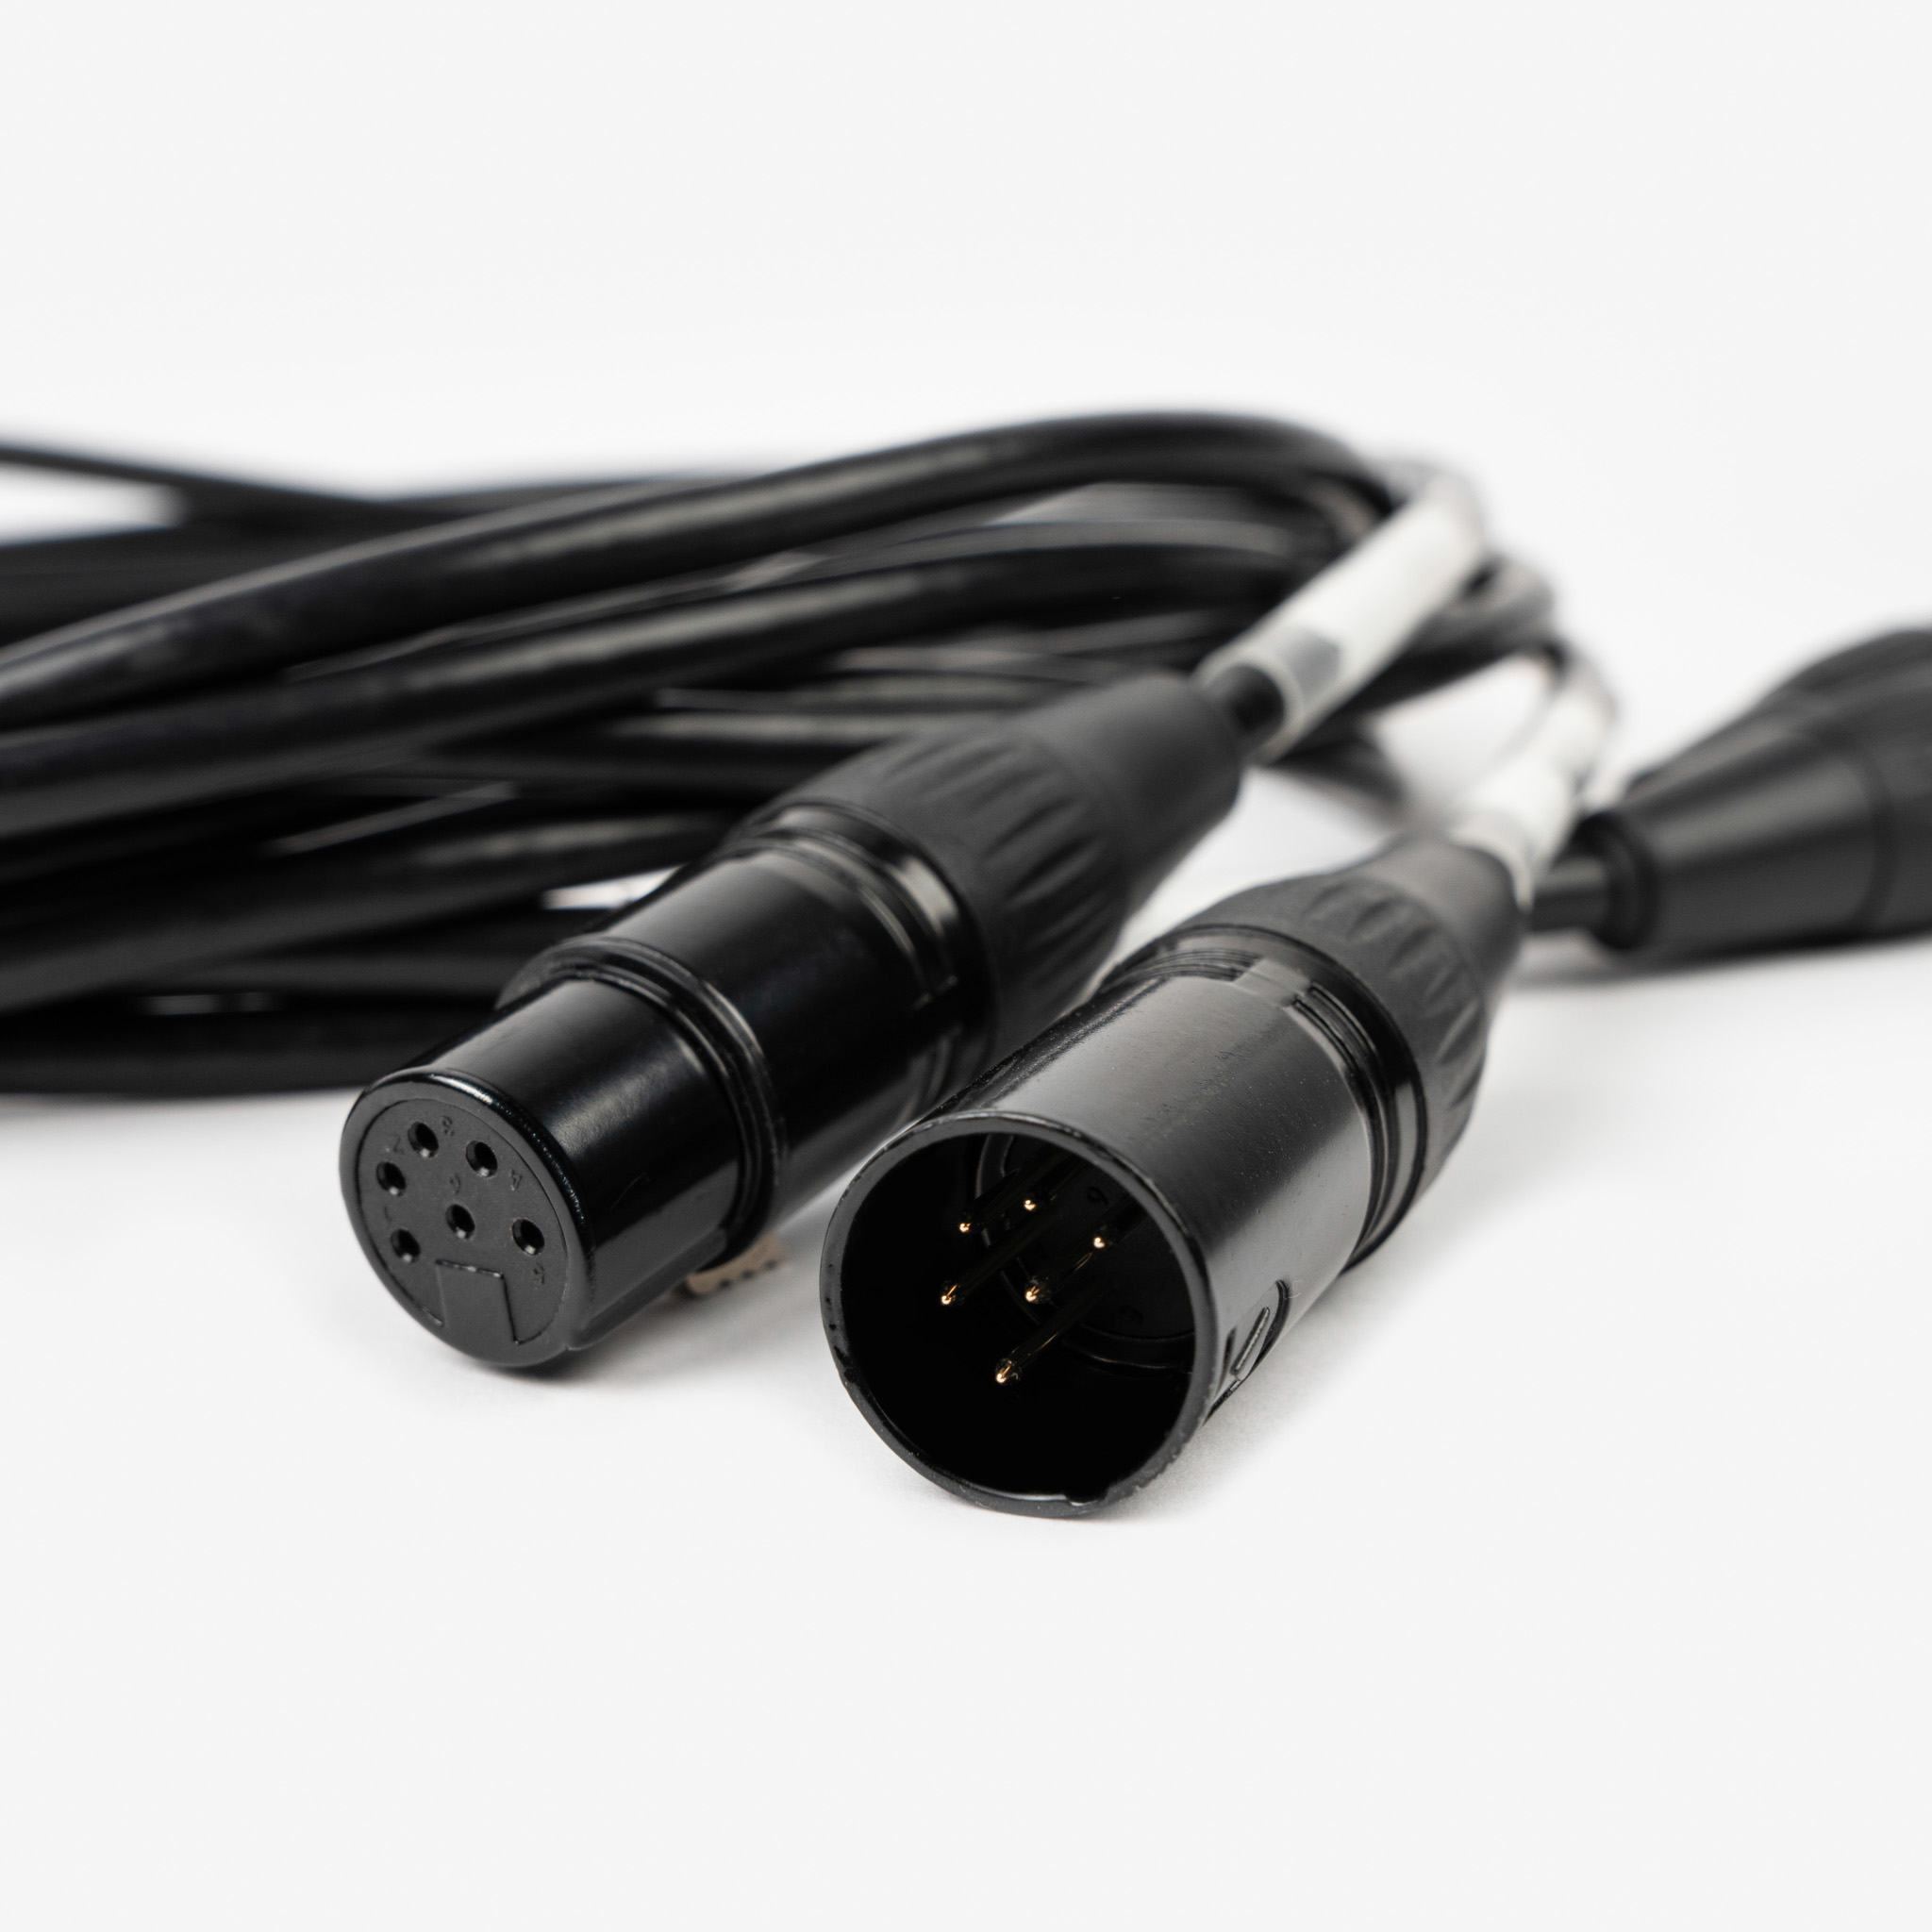
DMX512, sACN and Artnet control, with 5-pin XLR DMX connections and EtherCON control connectivity.
Lifting
Lift up to 80 kg
A 750 W servo motor, 12 m maximum lifting height and 100 cm/s maximum lifting speed, as listed in the beta specification.
Safety
Plan safety into the system
A 24 V safety loop connects the winches and safety components as part of the complete installation.
Integration
Connect the suspended load
Through connections are specified as PowerCON TRUE 1, 20 A and EtherCON, Cat6.
Technical overview
Technical specifications
Performance
Model
Xine Robotics DMX Winch
Type
WX8012
Max lifting capacity
80 kg (176.37 lb)
Min lifting capacity
5 kg (11 lb)
Max lifting height
12 m (40 ft)
Max lifting speed
100 cm/s (39.37 in/s)
Noise emission
≈50 dB at 1 m (3.3 ft)
Duty cycle
24 hours at full load
Power, control and connectivity
Power supply
200–240 VAC, 50–60 Hz, PowerCON TRUE 1
Power consumption
750 W
Motor
230 VAC, 750 W servo motor
Control
DMX512, sACN, Artnet
DMX connection
5-pin XLR
Control connection
EtherCON
Through connections
PowerCON TRUE 1, 20 A & EtherCON, Cat6
Positioning resolution
Updated soon
Dimensions and rigging
Weight
60 kg (132.277 lb)
Dimensions
937 × 312 × 686 mm
Top of truss to top of bar
93 cm (36.614 in)
Mounting clamp
4 × slim eye coupler, 42–52 mm (2 in)
Snap hook
2 × 8 mm (5/16 in), galvanized steel
Rigging bar
Length 652 mm (25.2 in); diameter Ø47 mm (Ø1.85 in)
Safety, wire and operating conditions
Safety system
Proprietary KLSTR control
Ambient temperature
5–40 °C (41–104 °F)
Lifting wire (2)
3 mm (1/8 in), 19 × 7 galv. steel (EN12385-4)
Minimum breaking load
588 kg (5766 N / 1296 lb)
Wire safety factor
>10
Fleet angle
None
Active spooling offset
83 mm (3.3 in)
Safety-loop voltage and architecture
Updated soon
Control and safety
Understand the system behind the movement.
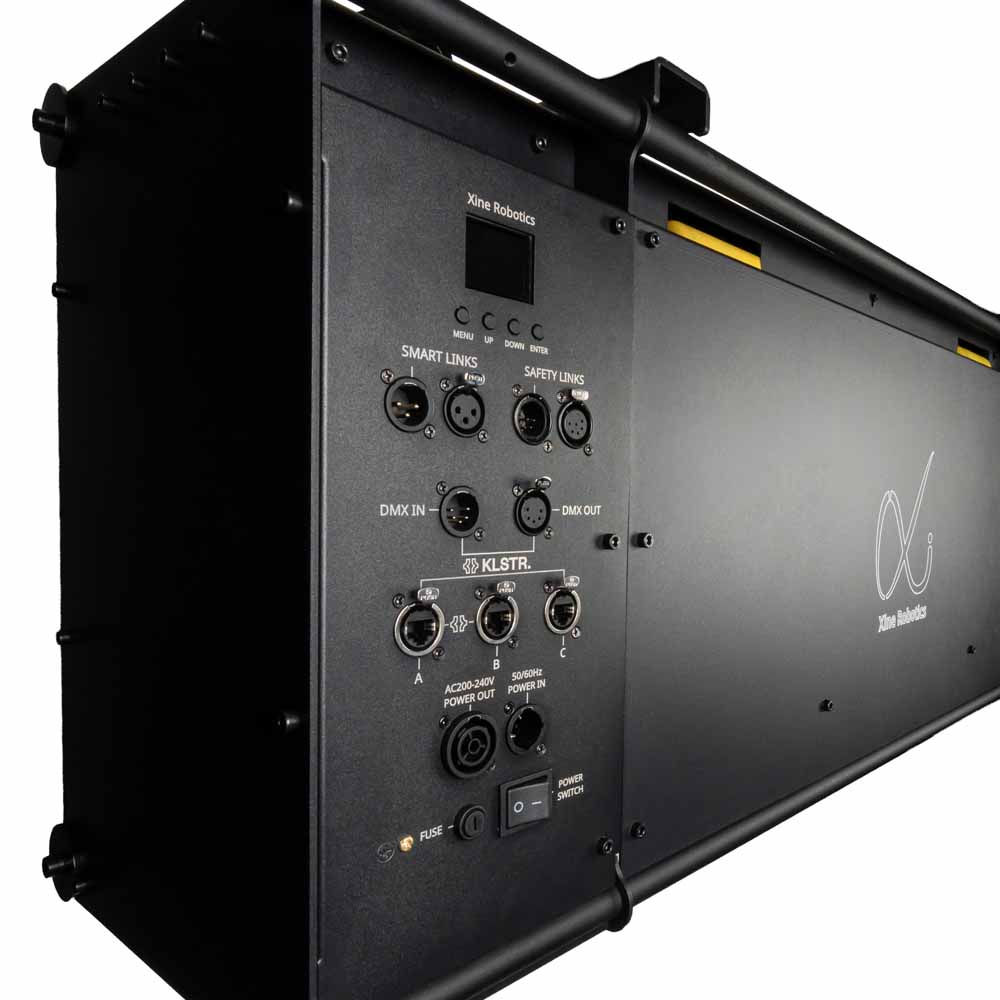
WX8012 connection panel and housing detail.
Configure, integrate and monitor
WX8012 combines KLSTR.one technology with network configuration through KLSTR.ctrl. Bring movement into familiar light and video control workflows, with monitoring of motion parameters across the installation.
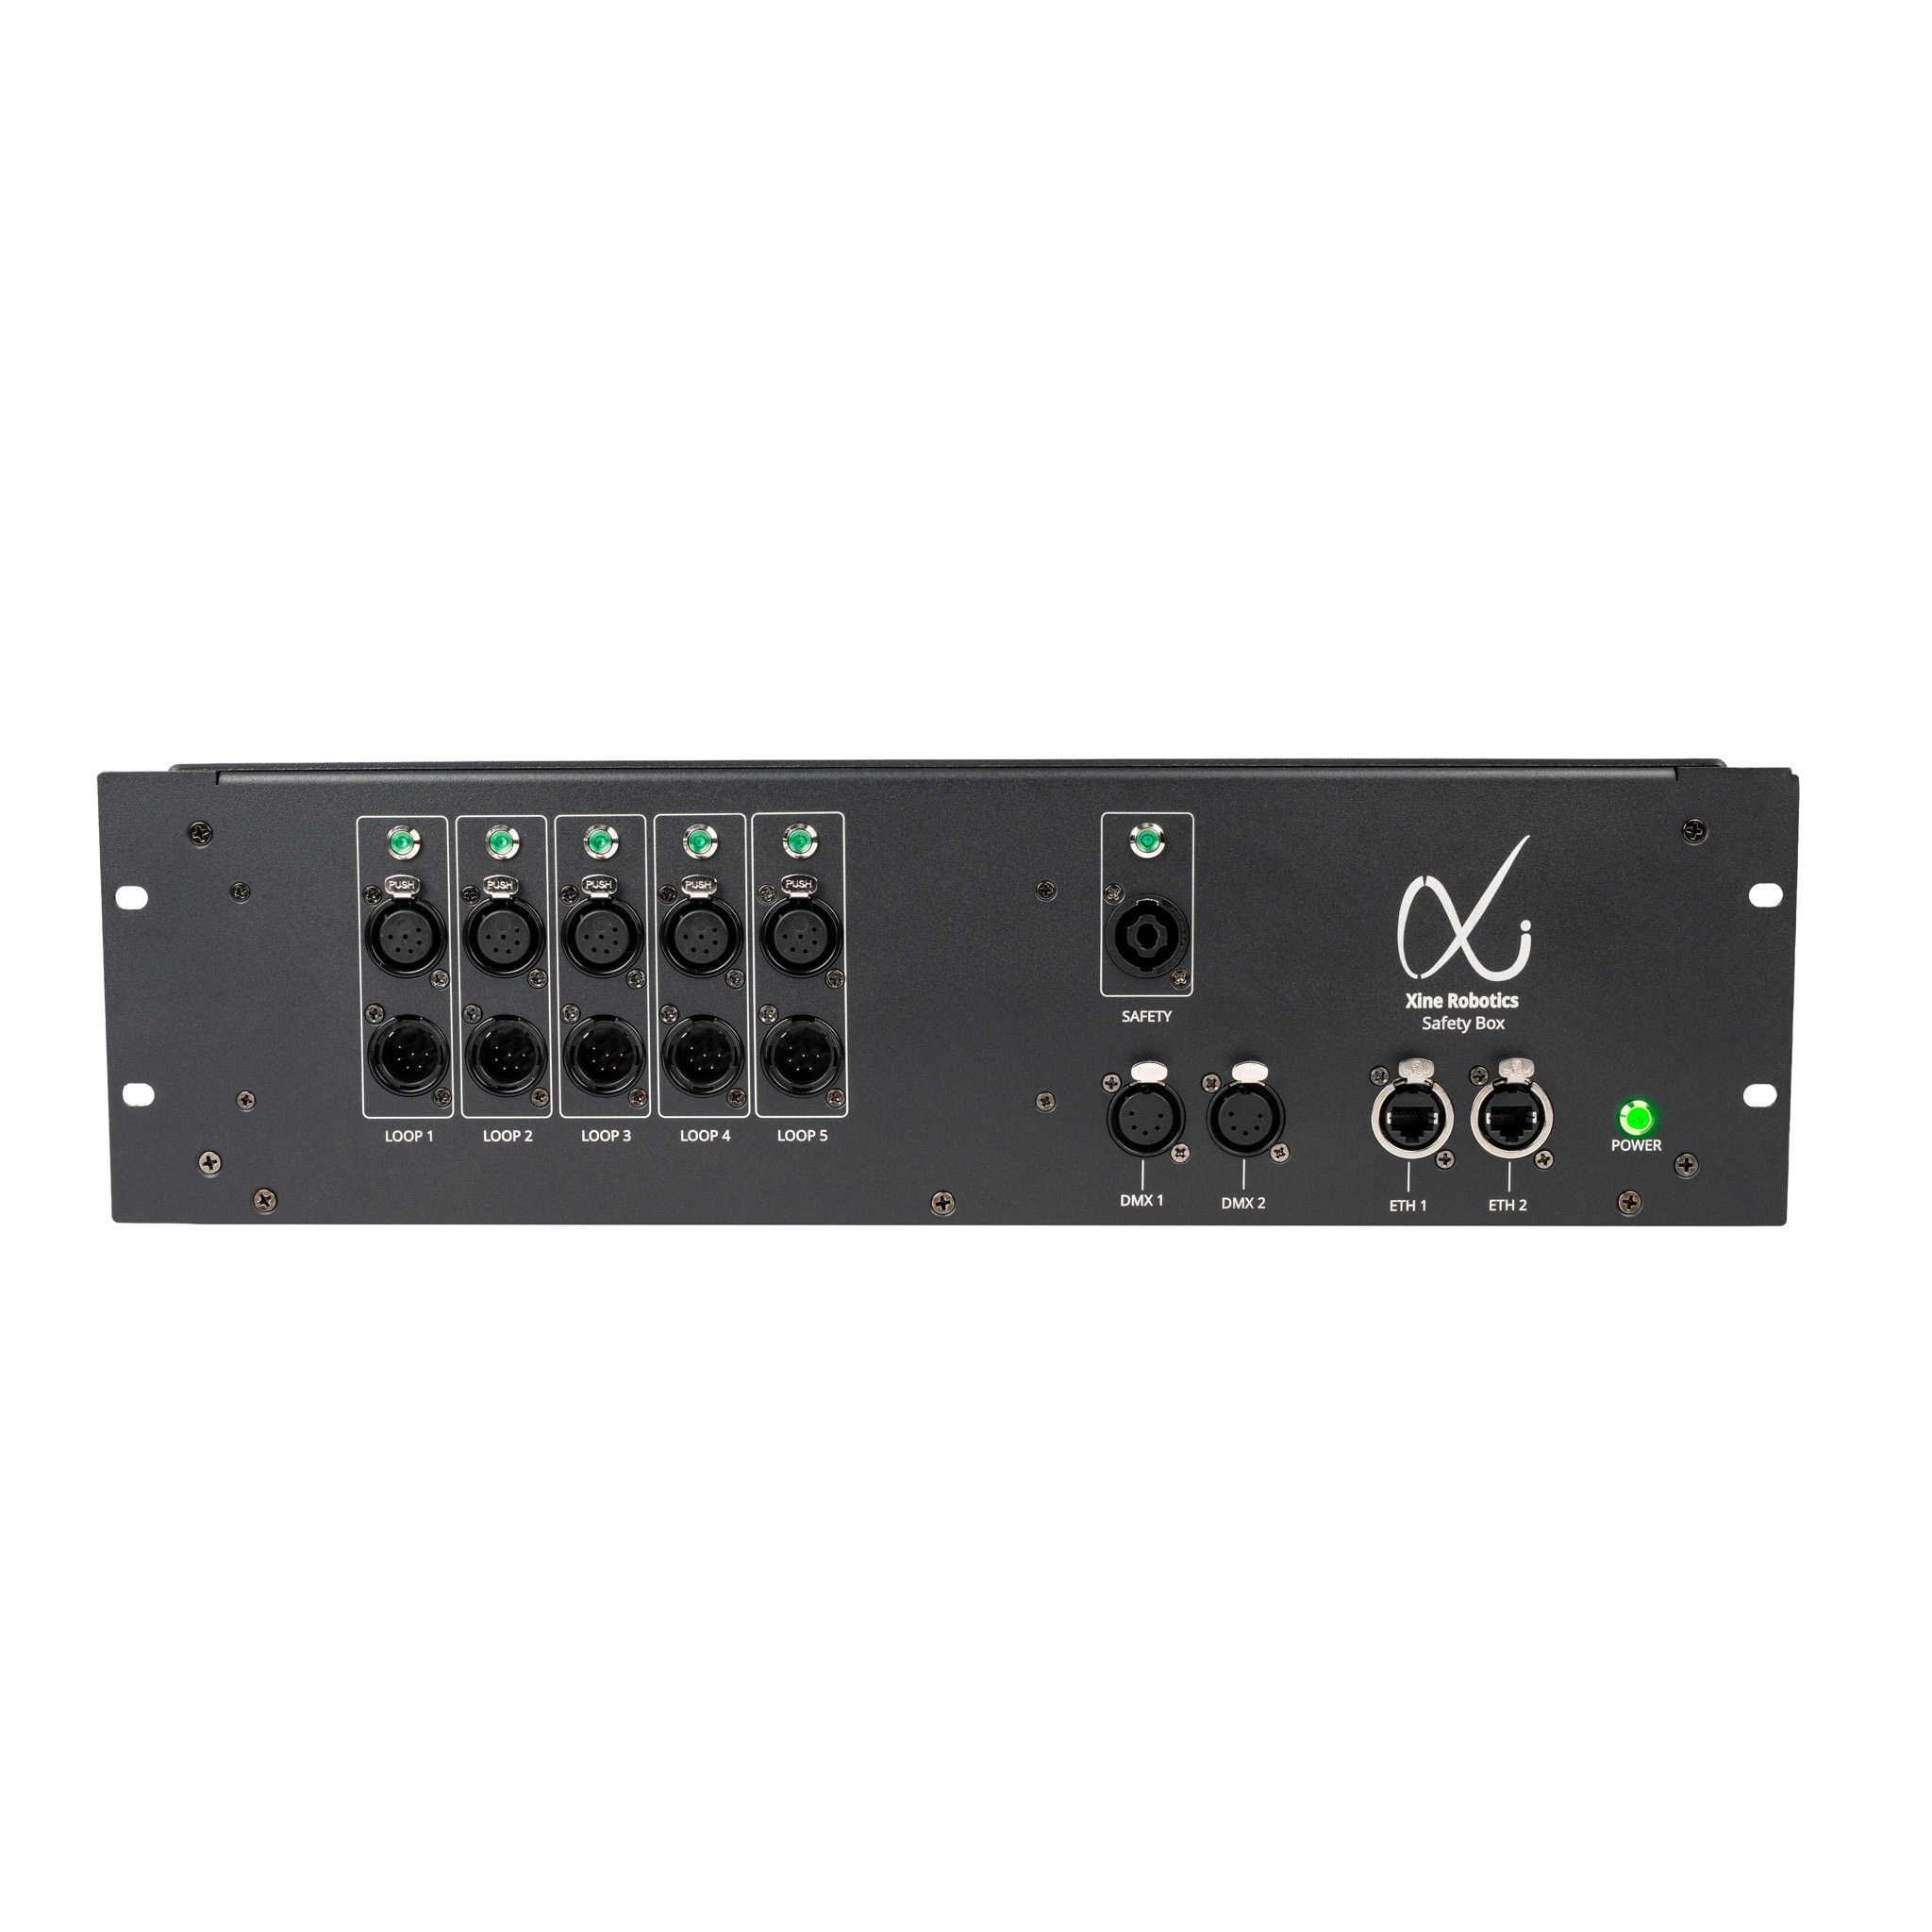
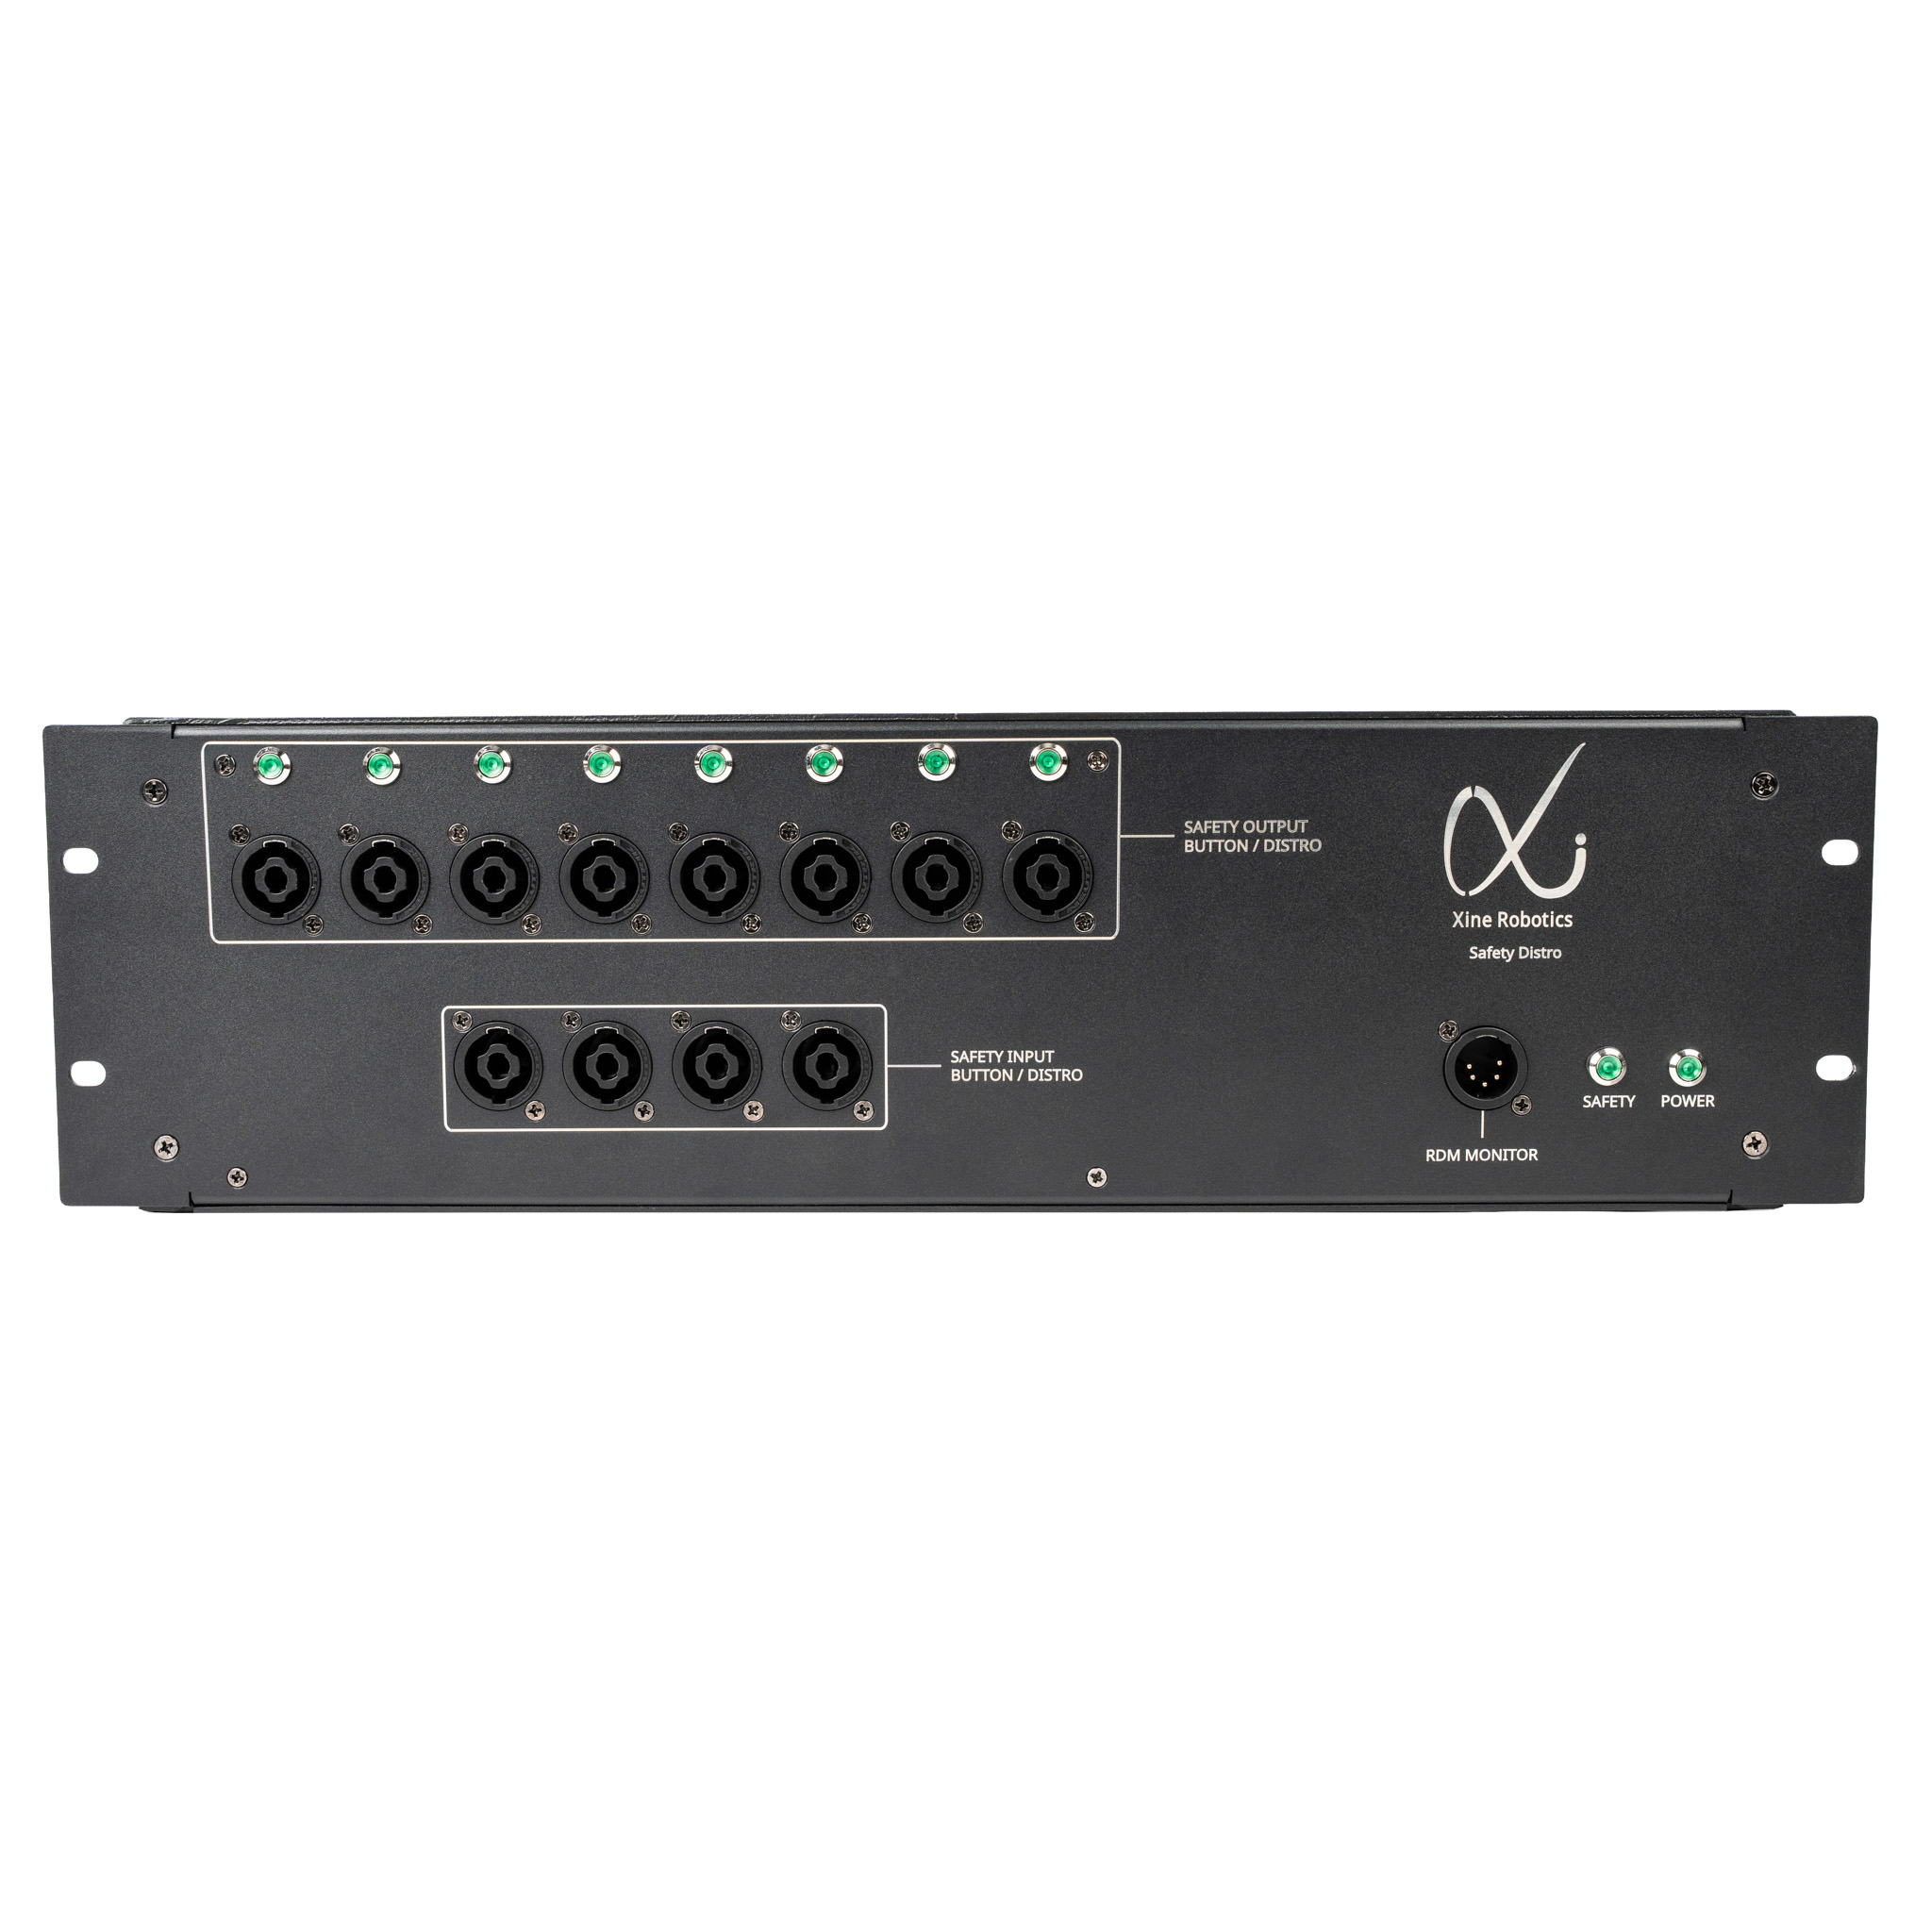
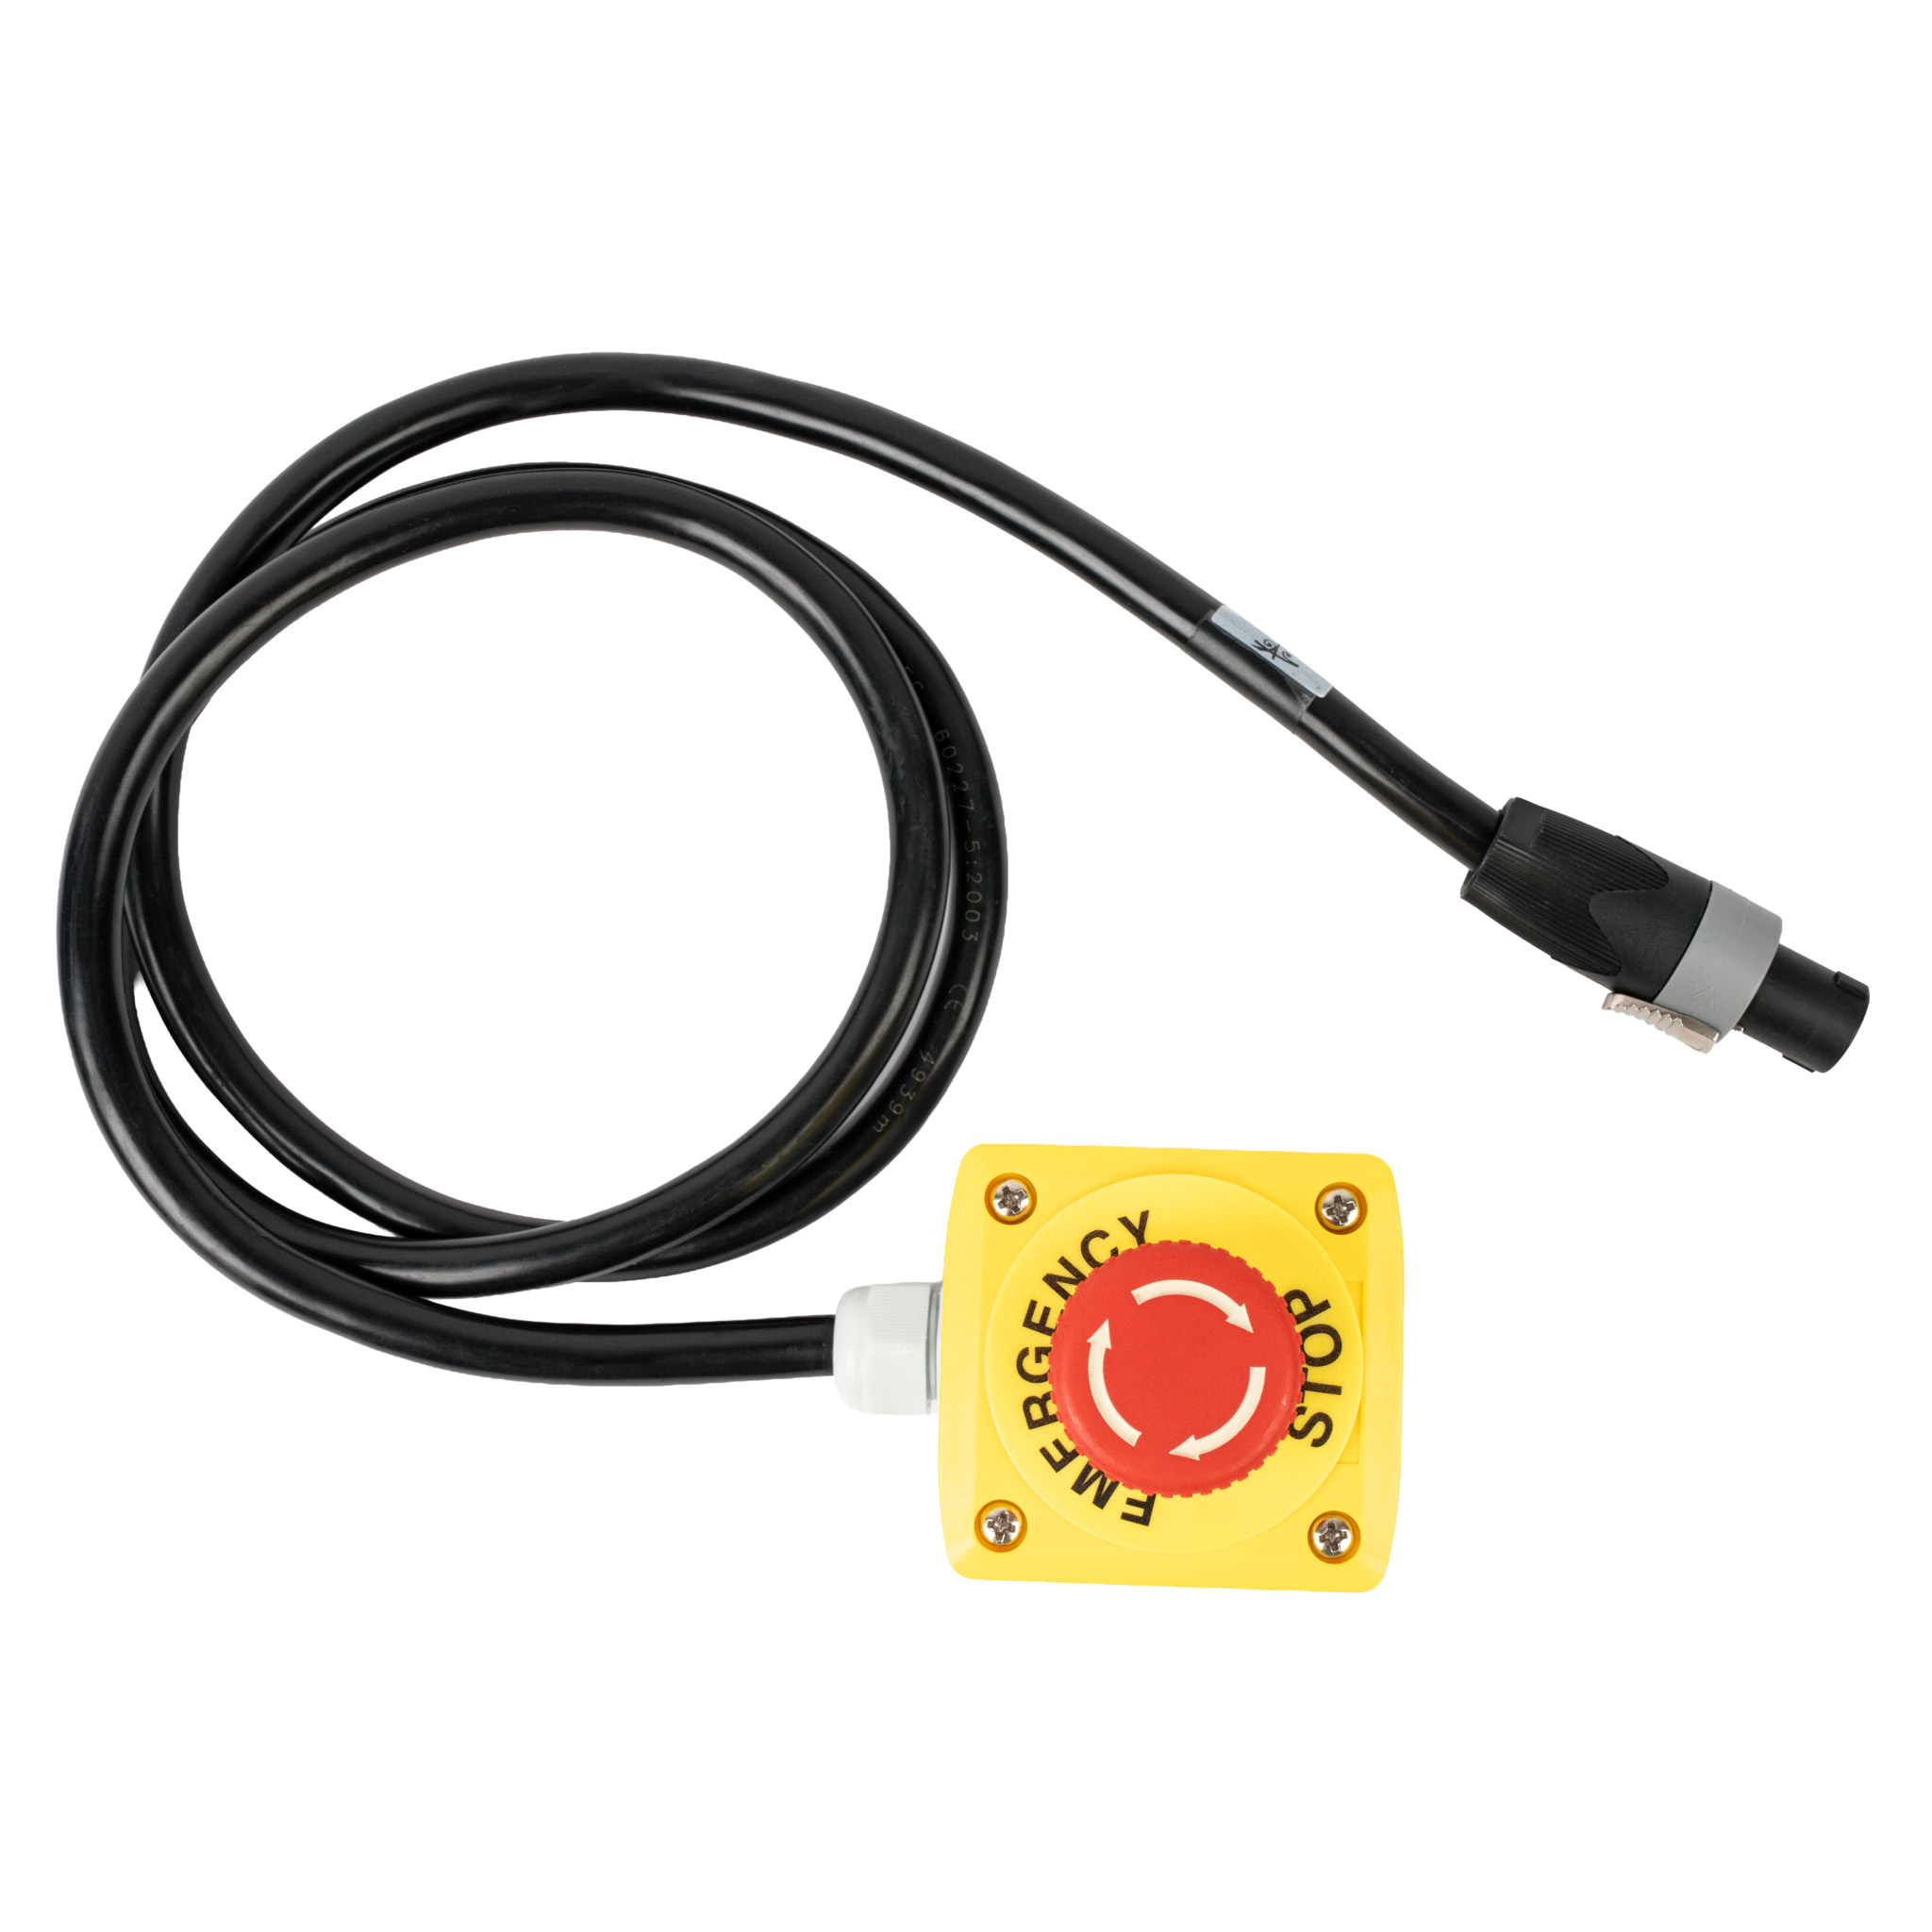
Keep motion control and safety distinct
The 24 V safety loop links the winches and safety components. Plan the safety system alongside the control network, and follow the documented installation, testing and operating procedures for the complete configuration.
Documentation and setup support
Request WX8012 documentationBuild your system
The winch is one part of the installation.
Motion-control path
DMX512 / sACN / Artnet
5-pin XLR DMX connections and EtherCON control connections.
Safety system
Proprietary KLSTR control
Downloads and support
The details, without the search.
The WX8012 beta specification has been transcribed into the technical section above. Missing document links and model-specific support information are marked below.
WX8012 spec sheet
PDF / 2 pages / 0.41 MB.
WX8012 user manual
System planning and training
Your next production
Specify WX8012 for your next production.
Tell us about the load, travel, control setup and number of winches you have in mind. Discuss a quotation, rental options or technical support with the team.
This enquiry is for WX8012. Include your project location and dates so the team can understand the setup.
info@xinerobotics.onePrefer to contact the team directly? Email info@xinerobotics.one and include WX8012 in the subject.

